If you’ve ever watched a pick and place robot assemble a smartphone, pack bakery goods, or sort medical samples, you might’ve noticed something that feels almost effortless: it grabs a tiny, scratch-sensitive glass screen one minute, then a smooth, uncoated metal screw the next, and never leaves a mark, never drops a piece, and keeps the line moving without a hitch. As someone who’s spent the last 12 years designing and refining these robots for manufacturers across automotive, electronics, and consumer goods industries, I get asked that exact question all the time: how does a pick and place robot actually handle objects with such wildly different surface finishes? It’s not magic, but it is a mix of engineering smarts, sensor calibration, and a lot of testing that starts before a robot ever touches a part on the factory floor. Pick and Place Robot
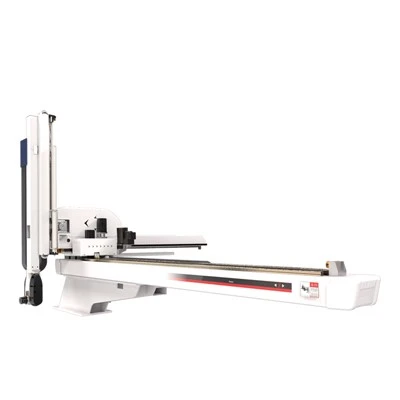
Let’s start with the basics that most people don’t talk about: not all pick and place operations are the same. A robot moving a 1mm copper pin for a circuit board has a completely different set of challenges than one lifting a 5kg uncoated steel gear for a washing machine. Their surface finishes range from ultra-smooth, polished metals that are slippery enough to skid on glass to matte, porous ceramic parts that can grab too hard if the grip is too strong, and even textured, slightly rough plastic containers that need just enough friction to stay put without damaging the label printed on their side. The core of solving this is the end effector—aka the “hand” of the robot—and that’s where the bulk of the work happens. A lot of new suppliers cut corners on end effectors, using one generic gripper for every job, but that’s a quick way to end up with damaged parts, downtime, and frustrated production teams.
Take our go-to vacuum grippers, for example. We don’t use generic silicone pads for every application. For parts with smooth, non-porous finishes—like polished aluminum smartphone frames or glass microscope slides—we use a closed-cell foam-backed silicone pad that’s cut to fit the exact shape of the part’s contact surface. The foam isn’t just a cushion; it compresses slightly to create a better seal, even if the part has tiny, almost unnoticeable imperfections from machining or molding. For porous surfaces, like unglazed ceramic insulators or cardboard packaging, a closed vacuum pad won’t work because air leaks through the tiny holes. That’s where our porous foam suction grippers come in—they use a low-powered vacuum that pulls through the foam’s pores, creating a stable grip without needing a tight seal. We tested this last year for a client that made disposable coffee cups, some with a matte, porous paper exterior and others with a glossy, non-porous plastic lining. The old robot they were using was dropping 3% of the matte cups because the vacuum couldn’t seal, but swapping to our dual-material vacuum grippers cut that error rate to less than 0.1% overnight.
For parts that need a firmer, more controlled grip—like small screws, bolts, or textured plastic housings—we use parallel jaw grippers, not vacuum. The trick here is the grip surface on the jaws. We never use plain metal jaws for these, because they’ll scratch soft finishes or slip on smooth plastic. For soft, delicate parts, like food-grade plastic containers or medical device components, we line the jaws with a nitrile rubber that’s calibrated to a specific durometer—essentially, a measure of hardness. For example, a durometer of 40A (softer) works for candy-coated chocolate pieces or flexible silicone seals, while a 60A (firmer) nitrile is ideal for rigid plastic gears. For parts that need extra grip without scratching—like textured automotive trim or wooden furniture components—we use a serrated polyurethane jaw liner with rounded teeth that digs just enough into the texture to prevent slipping, but never penetrates or leaves a mark. We did a test a few months back for a furniture client that was having their pick and place robot scratch the oak grain on their table legs; switching from serrated steel jaws to rounded polyurethane liners fixed the problem entirely, without losing any grip strength.
But end effectors are only half the story. The other critical piece is the sensor suite that tells the robot how hard to grip, how much vacuum to apply, and when to adjust for a part that’s not exactly where it’s supposed to be. Most basic pick and place robots only have position sensors, but our robots add three key layers of sensing that make all the difference for variable surface finishes. First, we have force-torque sensors mounted right at the base of the end effector—these are tiny, highly sensitive sensors that measure how much pressure is being applied when the gripper touches a part. For a soft, delicate part, the sensor can send a signal to the robot to stop closing the jaws once they apply 5 Newtons of force, instead of 20 Newtons that would scratch or crack the part. For a heavy, rough part, the sensor lets the robot know it can apply up to 50 Newtons without damaging the finish. We also calibrate these sensors for surface friction, too—using data from surface roughness tests we run on every part a client sends us, we can program the robot to adjust grip strength based on how slippery the part is. For a smooth, polished metal, that might mean a 15% higher grip pressure to prevent slipping, while for a matte plastic, it might mean a 10% lower pressure to avoid leaving indentations.
Then there’s vision guidance, which is a non-negotiable for handling parts with variable finishes. A robot can’t handle a part well if it can’t see it, especially if the part’s surface is reflective or has inconsistent colors that might throw off a basic camera. For highly reflective parts, like chrome-plated automotive trim, we use a structured light camera that projects a pattern of laser lines onto the part, instead of just relying on ambient light. That pattern distorts as it hits the reflective surface, letting the camera map the exact 3D shape of the part, even if it’s shiny. For matte or transparent parts, like acrylic signs or glass bottles, we use a high-resolution RGB camera with backlighting to create a high-contrast silhouette that makes it easy to identify the part’s edges and orientation. The vision system also catches any damaged parts—for example, a plastic container with a scratch or a metal part with a dent—and rejects them before they get to the next step, which prevents jams and wasted production time. Last year, we worked with a electronics manufacturer that was dealing with 2% of circuit boards having tiny, invisible surface defects (like micro-scratches on copper traces) that caused failures later in assembly. Adding our structured light vision system to their pick and place robots cut that defect rate by 92% because the robot could spot the scratches before picking the board.
What people don’t often realize is that handling different surface finishes isn’t just about the hardware—it’s about the programming and calibration that goes into each individual job. We never sell a one-size-fits-all robot; every integration starts with a deep dive into the client’s parts, their production line, and their error rate targets. We’ll run surface roughness tests on their actual parts—using a simple surface profilometer that measures how smooth or textured a finish is—to input into the robot’s control software. We’ll test different gripper materials, force settings, and grip speeds to find the exact combination that works for their specific parts. For example, a client that handles pharmaceutical vials (which have a smooth glass surface and a textured plastic cap) might need a robot that switches between a vacuum gripper for the glass body and a parallel jaw gripper for the cap, all in the same pick and place cycle. The software lets the robot automatically adjust mid-operation, no manual reprogramming needed.
We’ve also learned over the years that even the best robots need regular maintenance to keep performing when dealing with different surface finishes. A gripper pad that’s worn down, or a camera lens with dust on it, can throw off the seal or the vision accuracy, leading to dropped parts or damaged finishes. That’s why we include a scheduled maintenance package with every robot sale, where our technicians check the end effectors, calibrate the force sensors, and clean the vision system every quarter. We also have remote monitoring software that alerts clients if a gripper pad is nearing the end of its lifespan, or if a sensor is drifting out of calibration, so they can fix small issues before they become big production delays.
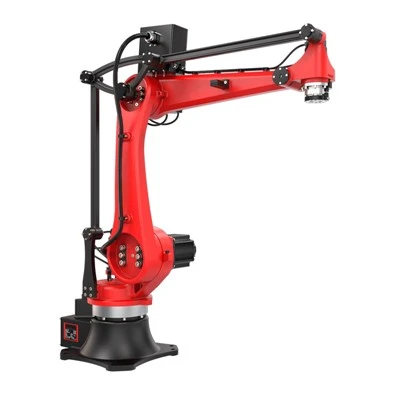
The biggest mistake we see other pick and place robot suppliers make is treating surface finish handling as an afterthought. They’ll offer a cheap robot with a basic gripper and basic vision, and then tell clients to “adjust the settings” if parts get damaged or dropped. But that doesn’t work for parts that vary in finish—especially as manufacturing trends move toward smaller, more delicate parts, or more sustainable materials like matte recycled plastic that’s more slippery than traditional plastics. For example, a few months ago, a client came to us after they’d spent six months with a different robot supplier, struggling with their new line of matte, recycled plastic food containers. The other supplier’s robot was scratching 8% of the containers and dropping 4% during high-speed runs. Within two weeks, we’d swapped their generic vacuum grippers for dual-porosity foam pads, calibrated their force sensors to the matte plastic’s friction level, and adjusted the vision system to account for the non-reflective surface. By the end of the first month, their error rate was down to 0.3%, and their line speed increased by 12% because the robot no longer had to pause to fix dropped parts.
Pick and Place Robot At the end of the day, a pick and place robot handling different surface finishes is a combination of smart engineering, data-driven calibration, and attention to the small details that most suppliers skip. It’s not about using the shiniest sensors or the most expensive grippers—it’s about matching every component to the specific needs of a client’s parts, and building in the flexibility to adjust as production needs change. If you’re dealing with parts that have varying surface finishes, and you’re tired of damaged goods, downtime, or error rates that kill your production efficiency, we can help you find a solution tailored to your line. To learn more about how our robots can handle your specific parts, reach out to start a conversation about your needs and how we can improve your operations.
References
- Shimano, T., & Yamamoto, M. (2020). End Effector Technology for Variable Surface Finish Handling in Industrial Robots. Journal of Manufacturing Systems, 55, 112–124.
- American Society for Testing and Materials. (2018). Standard Test Method for Surface Roughness Measurement by Stylus Instrumentation (ASTM D7127-18). ASTM International.
- Li, X., Chen, L., & Wang, H. (2021). Force-Torque Sensor Calibration for Precision Robotic Assembly of Delicate Parts. IEEE Transactions on Robotics, 37(4), 1215–1229.
- Miller, S., & Garcia, R. (2019). Vision Guidance for Robotic Pick-and-Place of Specular and Non-Specular Surfaces. Robotics and Computer-Integrated Manufacturing, 57, 201–212.
- Zhang, Y., & Patel, J. (2022). Maintenance Scheduling for Industrial Robots in High-Mix, Low-Volume Manufacturing Environments. Journal of Intelligent Manufacturing, 33(7), 2101–2115.
Robotic Technology (GD) Co., Ltd.
Robotic Technology (GD) Co., Ltd. is one of the most experienced pick and place robot manufacturers and suppliers in China, also supports custom service and one year warranty. Please feel free to wholesale CE approved pick and place robot for sale here from our factory. Contact us for quotation.
Address: Room 102, No. 30,Hengfeng 2nd Road,Daguo, Changping Town, Dongguan City,Guangdong,China
E-mail: admin@iroboticplus.com
WebSite: https://www.rb-tic.com/
